Boston Dynamics Atlas Next-Generation Four-Finger Robot Hand
- Hyundai Motor Group
- 2026.10.07 (KST)
- 분량2min
- 조회수 565Views
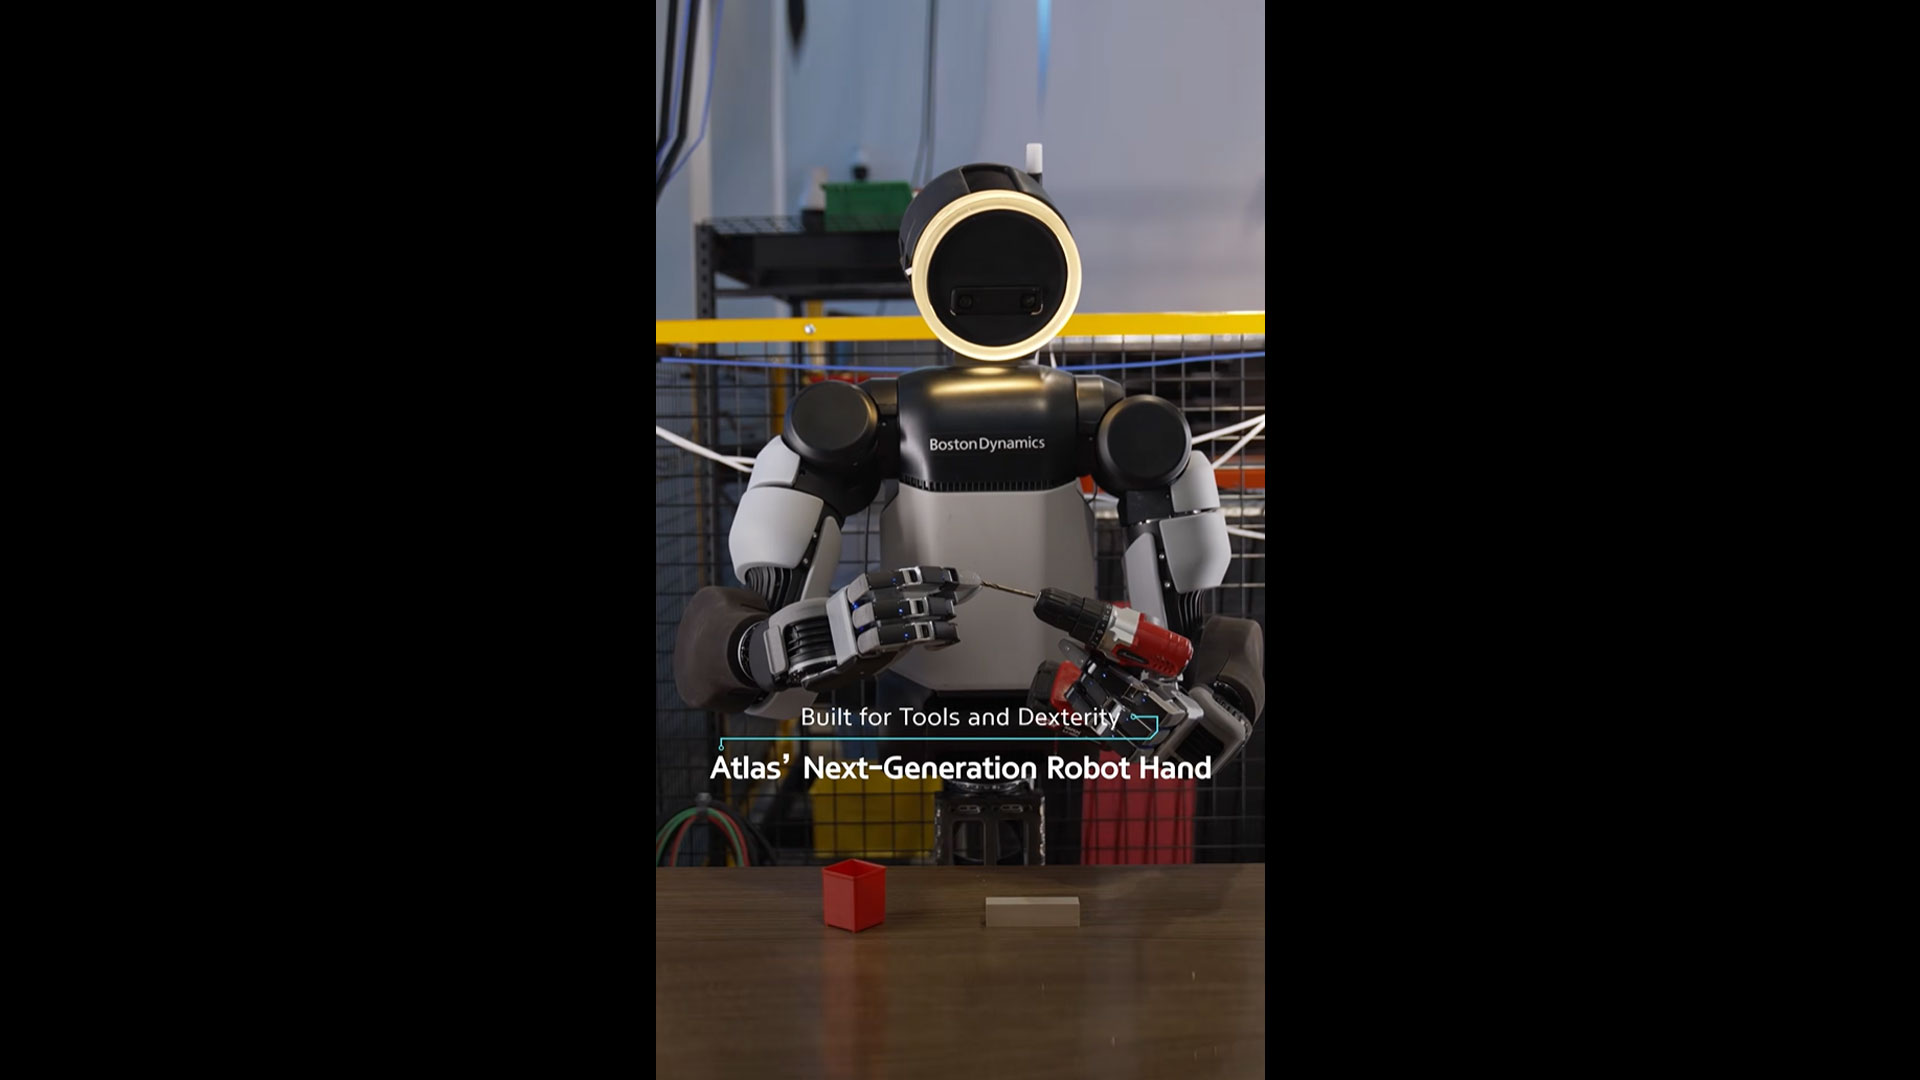
Tactile sensing helps detect subtle contact, while sim-to-real learning brings behaviors trained in simulation to real hardware, supporting precise manipulation for real-world industrial tasks.
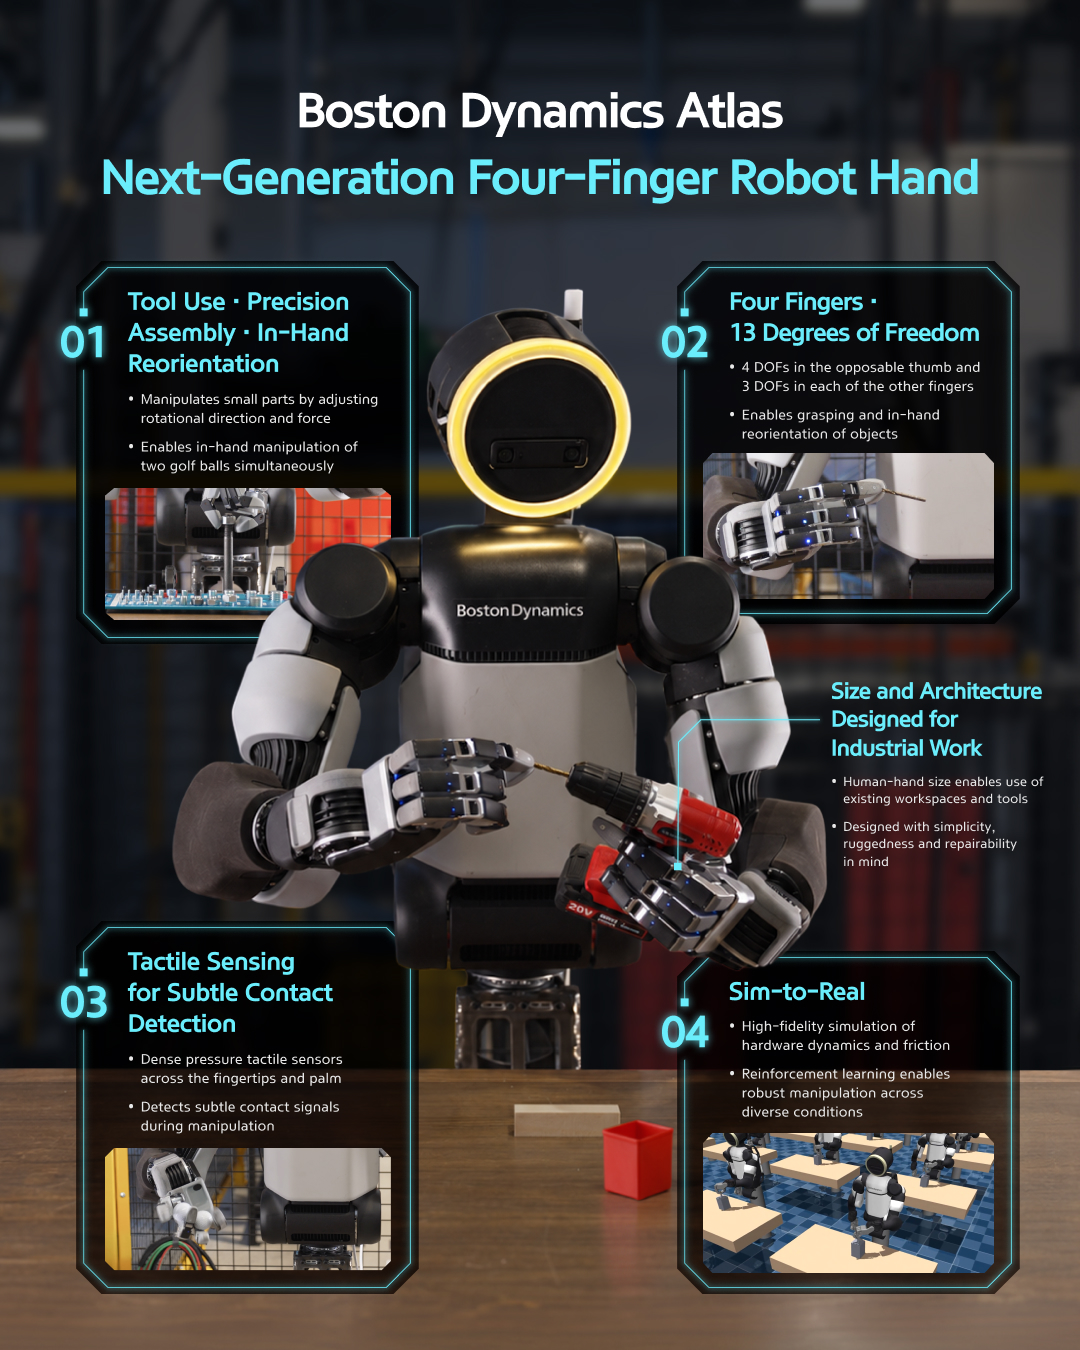
- Manipulates small parts by adjusting rotational direction and force
- Enables in-hand manipulation of two golf balls simultaneously
- Four Fingers · 13 Degrees of Freedom
- 4 DOFs in the opposable thumb and 3 DOFs in each of the other fingers
- Enables grasping and in-hand reorientation of objects
- Tactile Sensing for Subtle Contact Detection
- Dense pressure tactile sensors across the fingertips and palm
- Detects subtle contact signals during manipulation
- Sim-to-Real
- High-fidelity simulation of hardware dynamics and friction
- Reinforcement learning enables robust manipulation across diverse conditions
- Size and Architecture Designed for Industrial Work
- Human-hand size enables use of existing workspaces and tools
- Designed with simplicity, ruggedness and repairability in mind
Atlas’ dexterity comes from more than movement alone.
- Tool Use · Precision Assembly · In-Hand Reorientation
Manipulates small parts by adjusting rotational direction and force
Enables in-hand manipulation of two golf balls simultaneously
- Four Fingers · 13 Degrees of Freedom
4 DOFs in the opposable thumb and 3 DOFs in each of the other fingers
Enables grasping and in-hand reorientation of objects
- Tactile Sensing for Subtle Contact Detection
Dense pressure tactile sensors across the fingertips and palm
Detects subtle contact signals during manipulation
- Sim-to-Real
High-fidelity simulation of hardware dynamics and friction
Reinforcement learning enables robust manipulation across diverse conditions
- Size and Architecture Designed for Industrial Work
Human-hand size enables use of existing workspaces and tools
Designed with simplicity, ruggedness and repairability in mind